Projects

Machines and software I have built, most of them open source. Each one goes from analysis to simulation, and where possible to real hardware.
since 2022

3-RRR parallel manipulator: a planar robot steered by tilting an IMU

A planar 3-RRR parallel robot whose three servo legs move a platform in x, y and rotation, steered by a hand-held IMU or by ROS 2.

  • ROS 2 Humble
  • Gazebo
  • ros2_control
  • MuJoCo
Since 2019

Belt marking machine with laser integration

ROS 2 control software, a Gazebo digital twin and a touchscreen interface for a machine that feeds, laser-marks and cuts belts.

  • ROS 2 Humble
  • Gazebo
  • Raspberry Pi
  • Arduino Mega
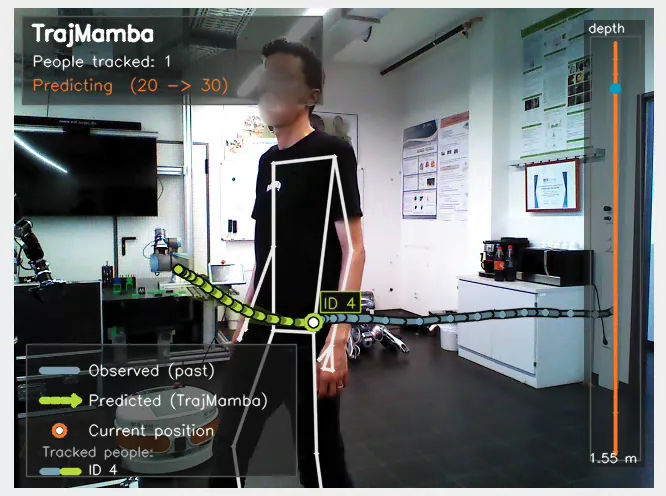
Camera view from a mobile robot showing a tracked person with a skeleton overlay, the observed walking path in blue and the predicted path in green
2026

TrajMamba: predicting where people will walk

A Mamba model that predicts the next three seconds of a person’s path from an RGB-D camera, in real time on a Jetson Orin.

  • ROS 2 Humble and Jazzy
  • PyTorch
  • Mamba
  • MediaPipe Pose
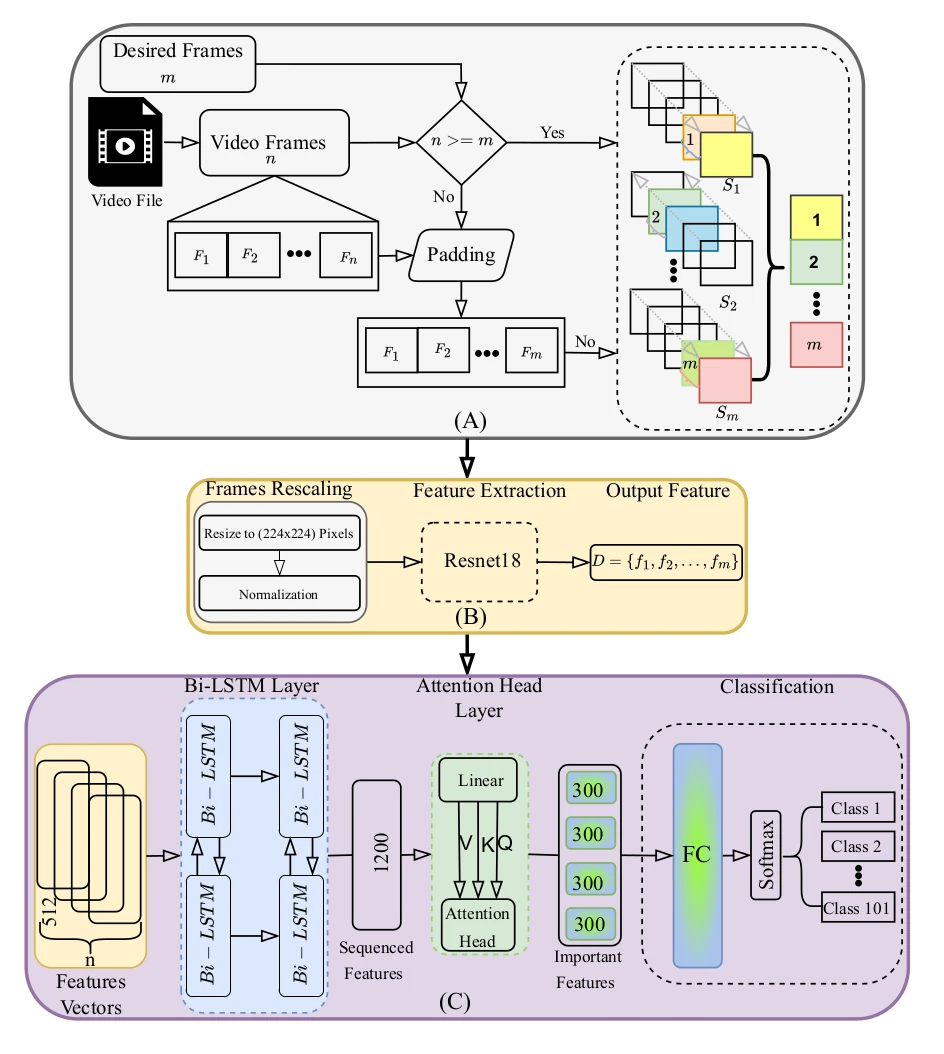
Architecture diagram in three stages - motion-based frame selection, ResNet-18 feature extraction, and a Bi-LSTM with an attention head feeding a classifier
2025

Human action recognition with ResNet, Bi-LSTM and attention

The official code for our Sensors 2025 paper. 96.6 % accuracy on UCF-101.

  • PyTorch
  • ResNet-18
  • Bi-LSTM
  • Multi-head attention
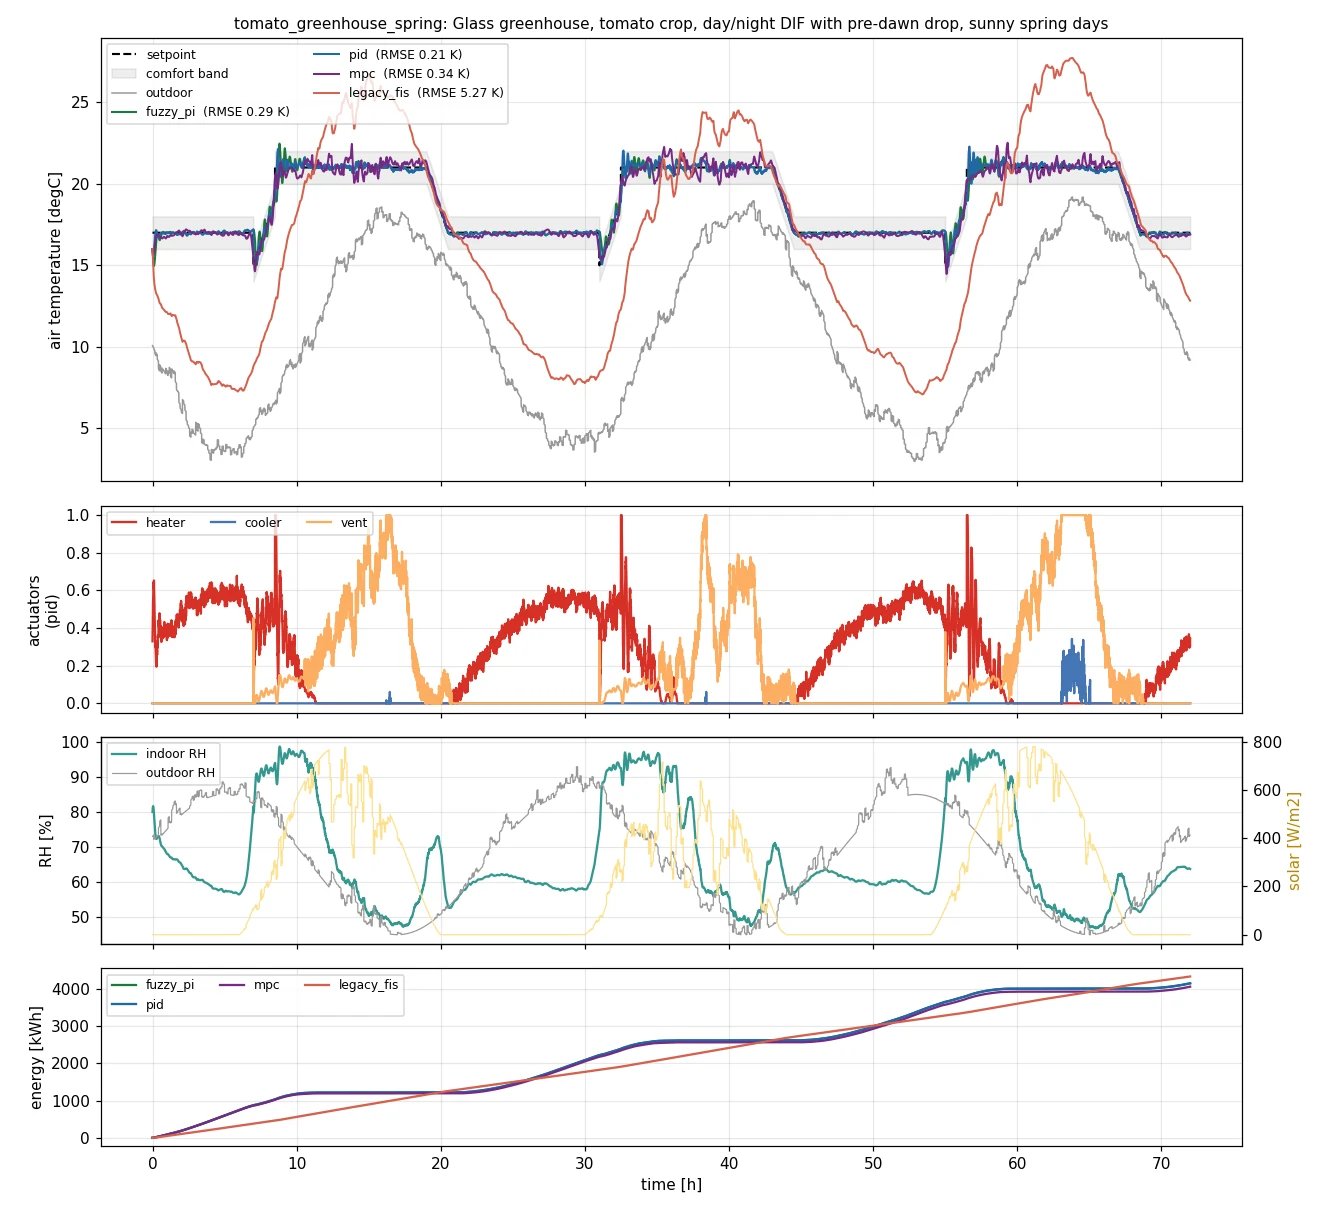
Benchmark plots of greenhouse air temperature, actuator commands, humidity and energy over 72 hours

Fuzzy greenhouse climate control

A fuzzy-PI controller with a digital twin, model predictive control and AI fault detection for greenhouses, vertical farms and cold stores.

  • Python
  • Fuzzy logic
  • MPC
  • ROS 2 Humble
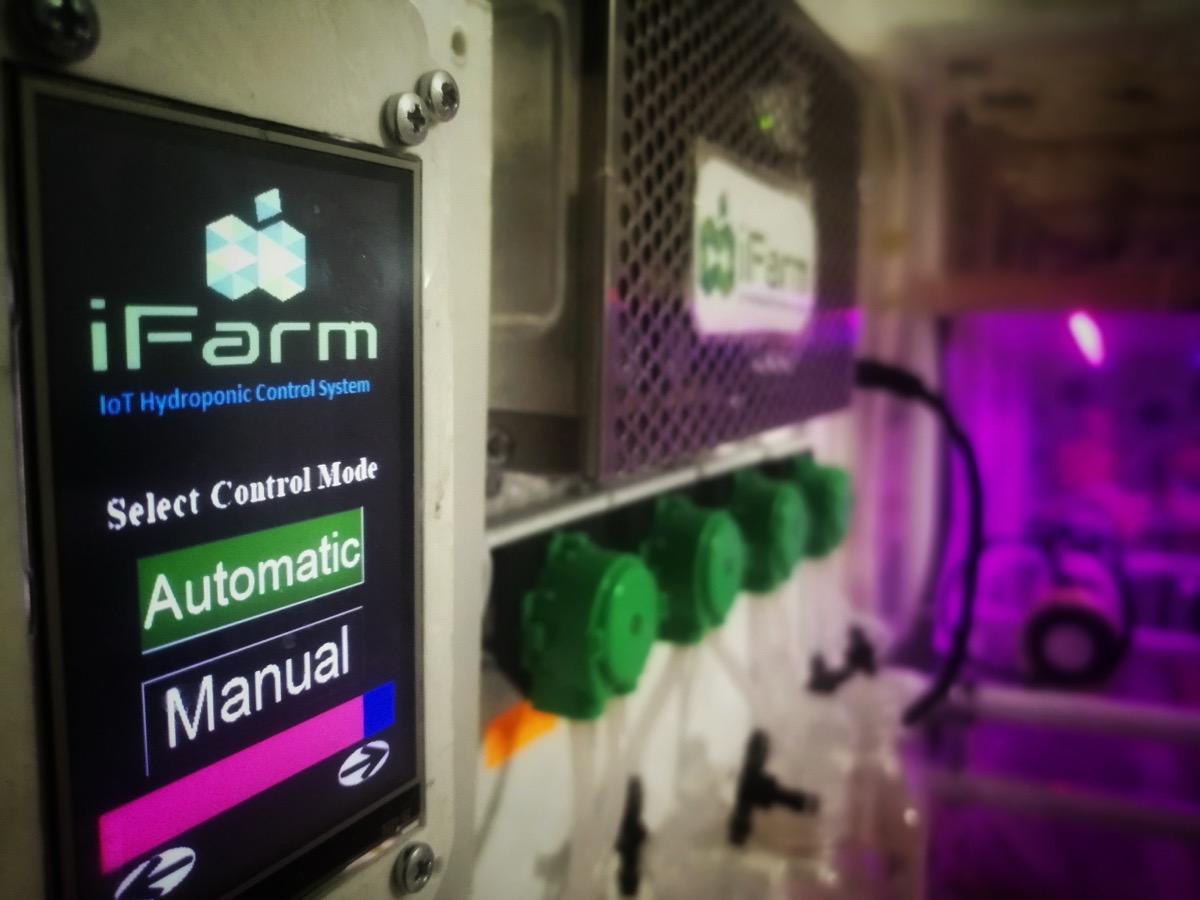
Control panel of the iFarm hydroponic automation system
2020 – 2022

iFarm: hydroponic farm automation

The start-up I founded in İzmir. A complete automation system for hydroponic growing, selected for ClimateLaunchpad and Accelerate2030.

  • Python
  • C
  • Arduino
  • Custom electronics

5-DoF robot arm with ROS MoveIt

A five-axis arm designed in SolidWorks, exported to URDF and planned with MoveIt in RViz and Gazebo.

  • ROS
  • MoveIt
  • Gazebo
  • RViz

Browse by topic