Basheer Al-Tawil
PhD researcher in Robotics and AI at Otto von Guericke University
Robots that map, understand and move among people.
I build the perception and navigation software that lets a mobile robot keep an accurate map while people walk through it, recognise what they are doing, and plan a path that respects their space.
From sensor data to polite motion
My work follows the data through a mobile robot, in five steps.
Results so far
How these were achieved- Error
Lower trajectory error than ORB-SLAM3 in scenes with moving people, from 0.404 m to 0.015 m on TUM RGB-D.
SAR-SLAM, Robotics 2026 - Accuracy
Higher Action Recognition accuracy on UCF-101 with a ResNet-18, Bi-LSTM and attention model that runs on a mobile robot.
Sensors 2025 - Goals
High percentage of navigation goals reached after fusing four RGB-D cameras with two LiDARs for 2D mapping.
Sensors 2025 - Citations
More than 140 citations for my review of visual SLAM methods for robotics, my most-cited paper.
Frontiers in Robotics and AI 2024
Selected publications
All 13 publications-
2026
SAR-SLAM: Semantic-Aware Recognition for Dynamic SLAM in Robotic Applications
Basheer Al-Tawil, Magnus Jung, Thorsten Hempel, Ayoub Al-Hamadi. Robotics 15(7), 136, 2026
-
2025
Mobile Robot Navigation with Enhanced 2D Mapping and Multi-Sensor Fusion
Basheer Al-Tawil, Adem Candemir, Magnus Jung, Ayoub Al-Hamadi. Sensors 25(8), 2408, 2025
-
2025
Multi-Head Attention-Based Framework with Residual Network for Human Action Recognition
Basheer Al-Tawil, Magnus Jung, Thorsten Hempel, Ayoub Al-Hamadi. Sensors 25(9), 2930, 2025
-
2024
A Review of Visual SLAM for Robotics: Evolution, Properties, and Future Applications
Basheer Al-Tawil, Thorsten Hempel, Ahmed Abdelrahman, Ayoub Al-Hamadi. Frontiers in Robotics and AI 11, 1347985, 2024
Open-source projects
All 9 projectsRoboCraft: a reconfigurable three-arm SCARA cell
Three SCARA robots that work alone or lock onto a hexagonal platform and become one parallel robot.
- ROS 2 Humble
- Gazebo Fortress
- ros2_control
- C++17
AgroBot: a robot arm for greenhouse work
A 4-axis arm on a rail trolley that harvests strawberries, transplants seedlings, inspects plants and pulls weeds.
- ROS 2 Humble
- Gazebo Fortress
- ros2_control
- C++17
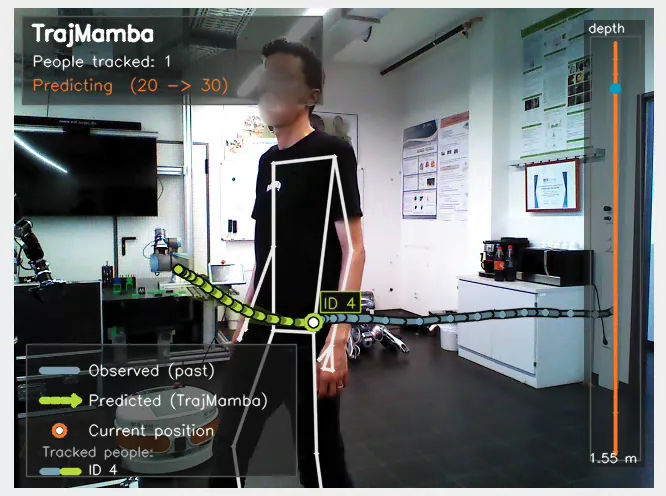
TrajMamba: predicting where people will walk
A Mamba model that predicts the next three seconds of a person’s path from an RGB-D camera, in real time on a Jetson Orin.
- ROS 2 Humble and Jazzy
- PyTorch
- Mamba
- MediaPipe Pose
Tutorials and notes
All 19 posts-
How to run your own local AI coding agent with Ollama and OpenCode
A step-by-step guide to running a private AI coding assistant on your own GPU. Install Ollama, choose an open model such as Qwen, tune VRAM, context length and KV cache, connect the OpenCode terminal agent, and fix the common errors.
Tutorials14 min read -
Host a website for free with GitHub and Cloudflare, step by step
How to take a website from a folder of files to a live address with your own domain, HTTPS, free email forwarding and visitor statistics. Design, repository, Cloudflare deployment, domain, launch checklist and measuring, with the mistakes to avoid.
Tutorials15 min read -
Sending a designed HTML email from Gmail, explained simply
Why a beautiful email can arrive empty, what Gmail keeps and removes, two reliable ways to paste a designed email into Gmail, the three traps to avoid, and a short Python checker for your HTML.
Tutorials9 min read
Work with me
I am open to research collaborations, industry R&D roles, postdoc positions and invited talks on mobile robotics, SLAM, perception and human-robot interaction.