5-DoF robot arm with ROS MoveIt
A five-axis arm designed in SolidWorks, exported to URDF and planned with MoveIt in RViz and Gazebo.
- Origin
- Course project
- Built with
- ROS
- MoveIt
- Gazebo
- RViz
- URDF
- SolidWorks
A compact exercise in the full path from CAD to motion planning. The arm has a prismatic base joint, a chain of revolute joints and a gripper.
Steps
- Mechanical design of the links and joints in SolidWorks.
- URDF export, with meshes, joint limits and inertial properties, for RViz and Gazebo.
- Controllers defined in YAML for each joint.
- MoveIt configuration for planning and executing collision-free trajectories.
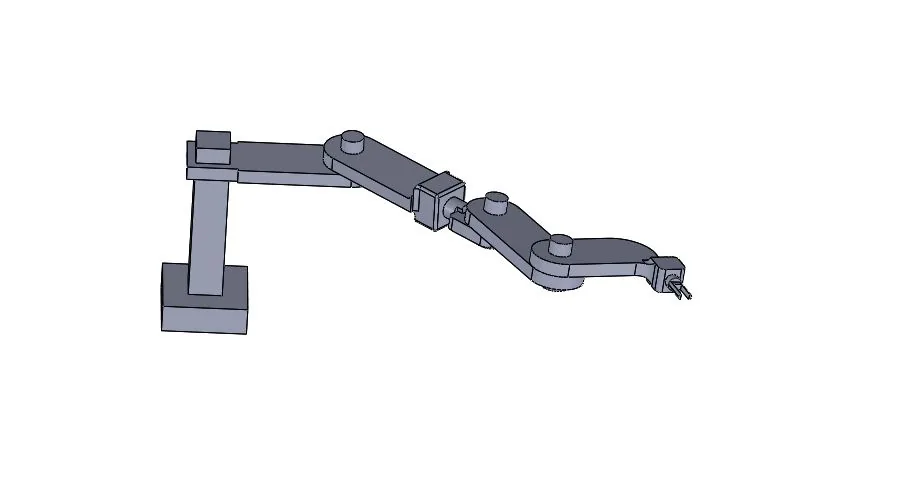
The repository includes the SolidWorks parts, the URDF, launch files for RViz and Gazebo, the MoveIt configuration package and a step-by-step PDF for launching everything.